on
ROSCon 2026, Toronto!
This year I attended another ROSCon Global, this time in my backyard, Toronto!
I don’t actually spend that much time in Toronto to I quite enjoy myself this time around even though I am somewhat used to travelling to some new place for ROSCon every year.
This post will be my summary of the event and some thoughts that I have as usual.
Key Takeaways
Physical AI
I think the way Physical AI working group defines their goals makes a lot of sense to me. It’s about enabling the capture of data, producing models and deploying those models onto real systems. However there is a bit of a tear between the practice aspects of physical AI and the aspirational ideas. At ROSCon there seemed to be a divide between people and companies trying to find a purpose for their physical AI applications and the more hardware focus companies that enablet physical AI to exist.
On vendor I had spoken to didn’t seem to know what the purpose of their product was. Only that they would trust the cloud hosted models would get powerfully enough for their robot to have an application. This is certainly an interesting take, but I just can’t seem to wrap my head around it.
I’m more on the hardware integration side of things. What I have thought to myself and have told my co-workers is that I think we do have a place in this new world of physical AI because the common denominator is always the hardware. So to me it’s interesting to see where things are headed and I want to try my best to participate in the community to understand where I belong in it.
Performance
I don’t think there was much word on new transport for middleware in ROS. There was talk about some of the new in-memory transport options like ROS IDL Buffers. I have some vegaue thought on this for hardware accelerated drivers or something to that degree but I’m not sure on the practicallity of it. Interesting none the less.
Robot Controllers
A few things of note here. I got to see the new Arduino board, the VENTUNO Q. This seems like a great option for robotics as it can host a linux operating system and has an STM32H5 for real-time tasks. I’ve want to get my hands on one and play around with it. Of course I have a tendency to buy these things and do nothing with them so I have to be cautios on that front lol.
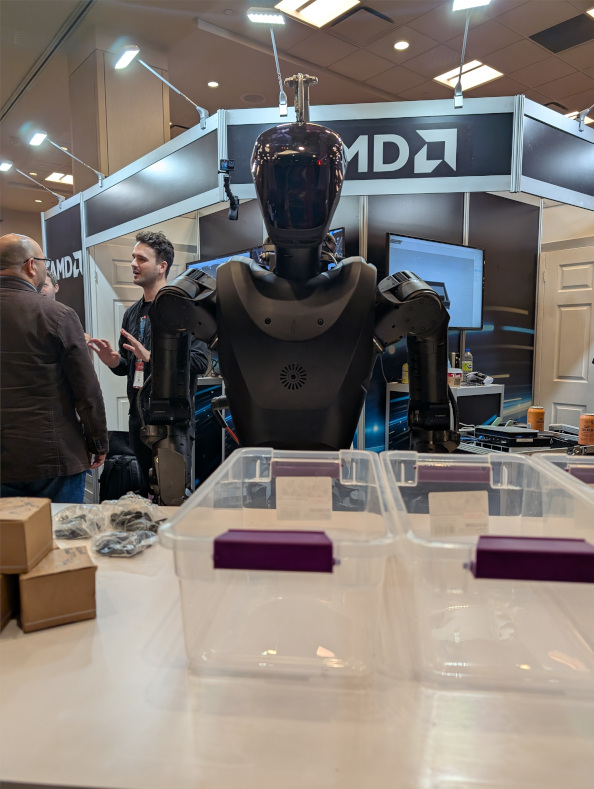
AMD also announced there new robot dev kit. It defintively has an automotive focus given the to CAN bus ports. Lots of compute. Of course not something I can try myself, but might be something really useful for industrial AMRs.
A lot of automation companies are also doing there “soft PLC” type thing. So Siemens. And AMD and Intel now have robot development platforms to work with.
Robots!
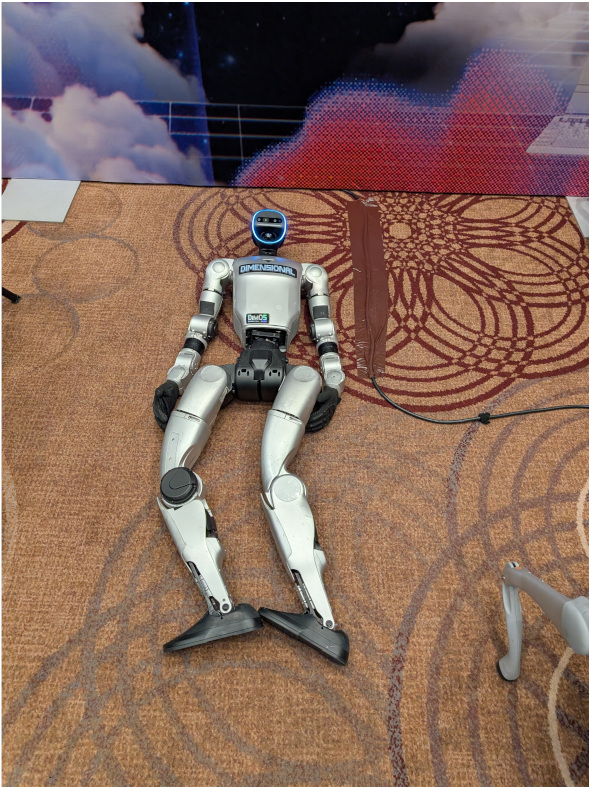
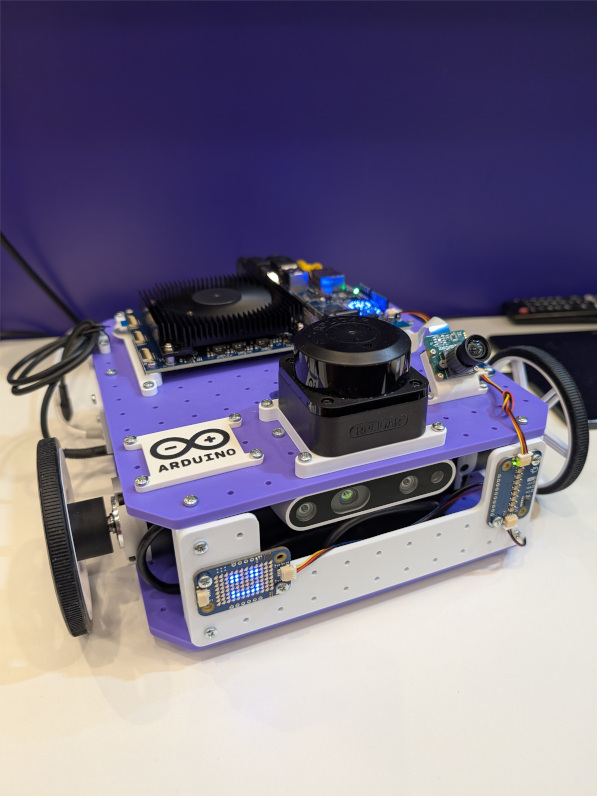
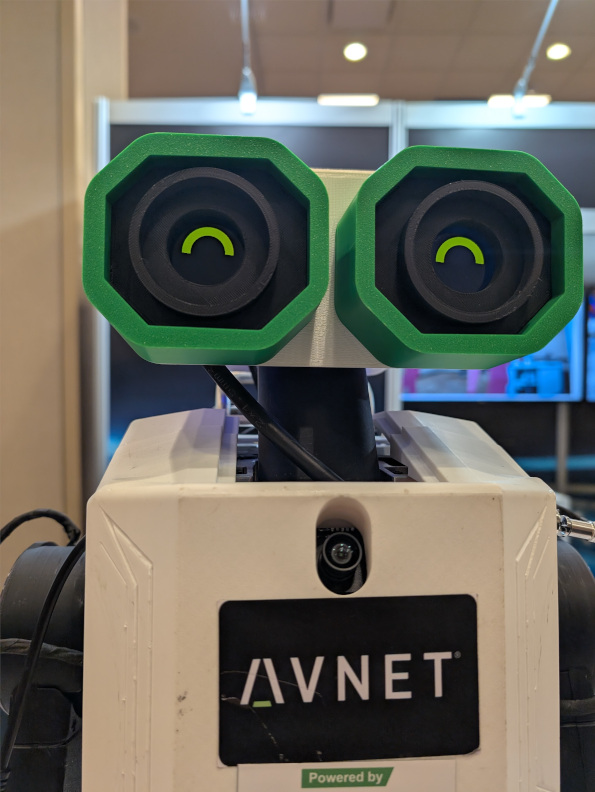
Toronto